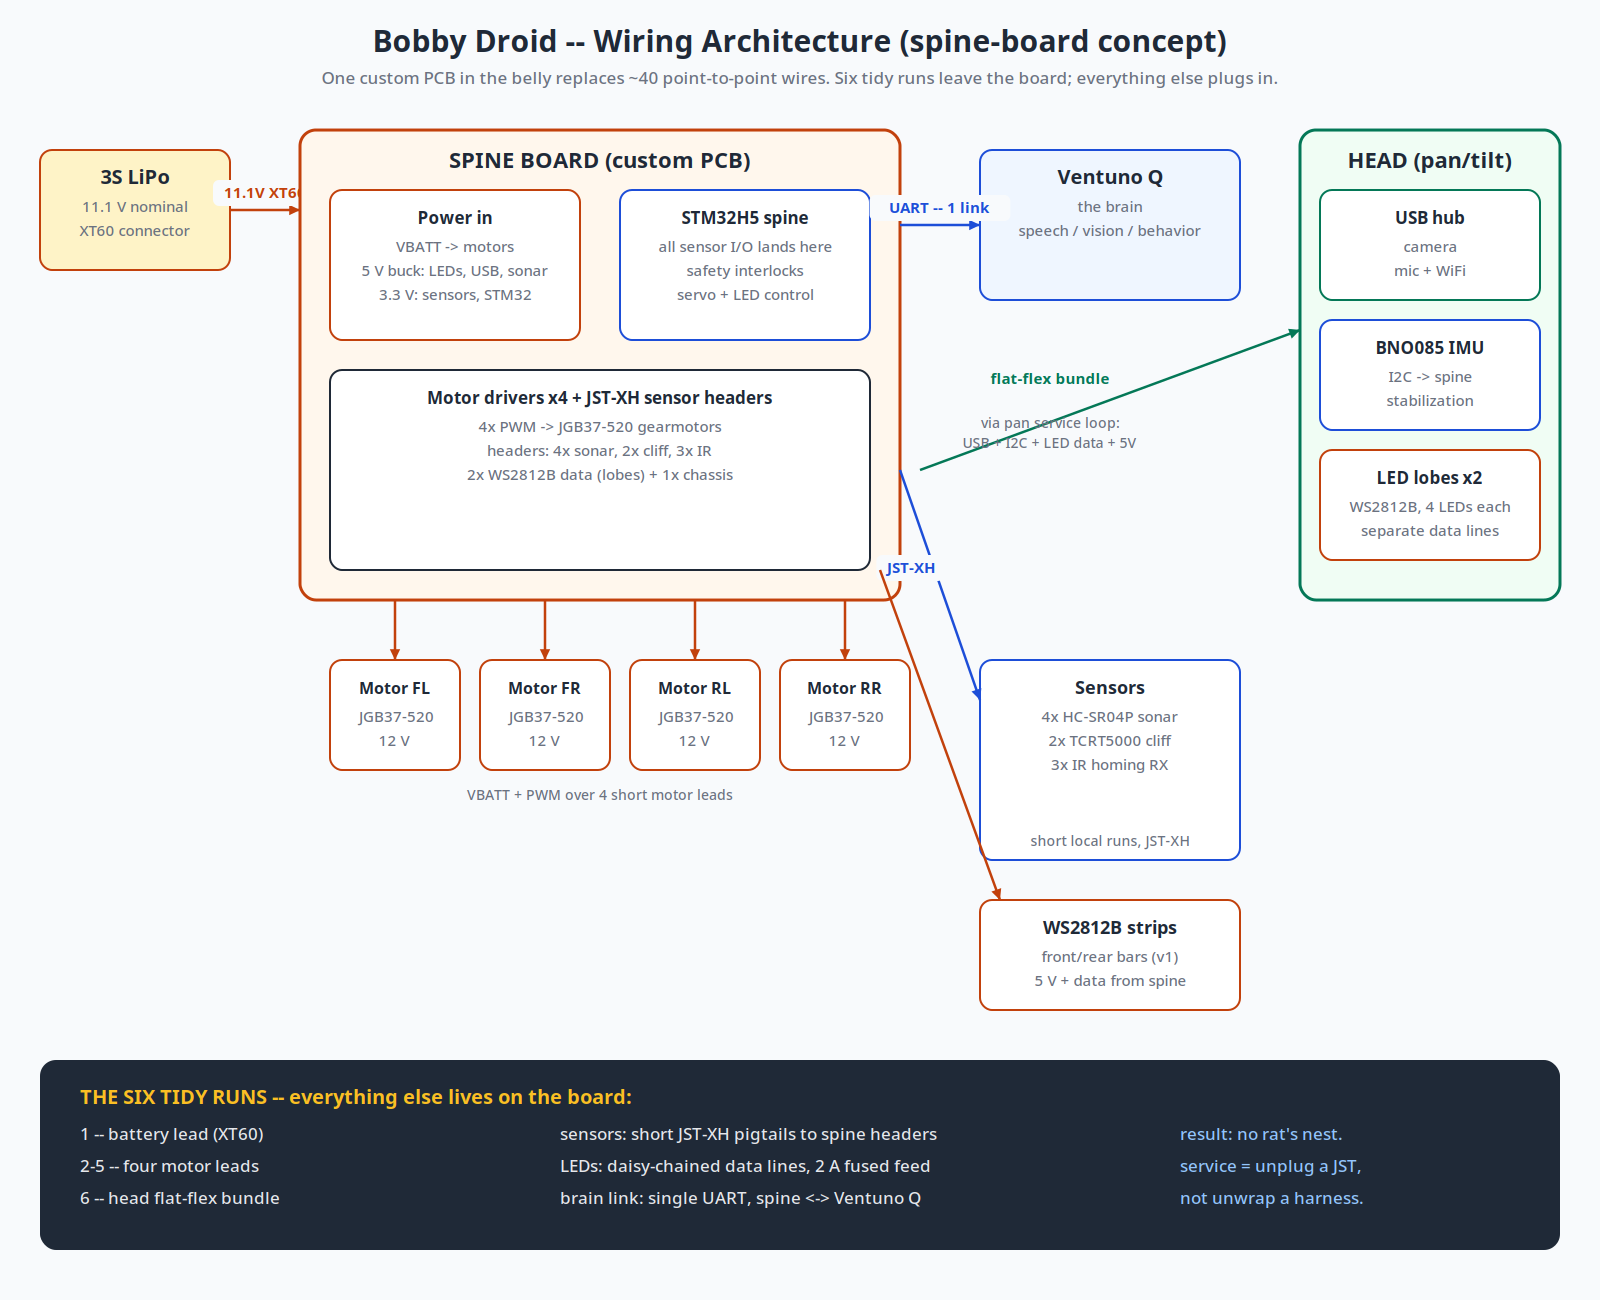
Killing the wire rat's nest
Every past Pi/Arduino project ended in a harness hairball. This time the fix is a custom spine PCB: six tidy runs, everything else plugs in.
A from-scratch friendly droid: four-wheel skid steer, pan-tilt head, onboard AI, and a safety-first architecture — designed in the open, one phase at a time. Budget: $1,000. Patience: unlimited.
Follow the build What is MechSmith?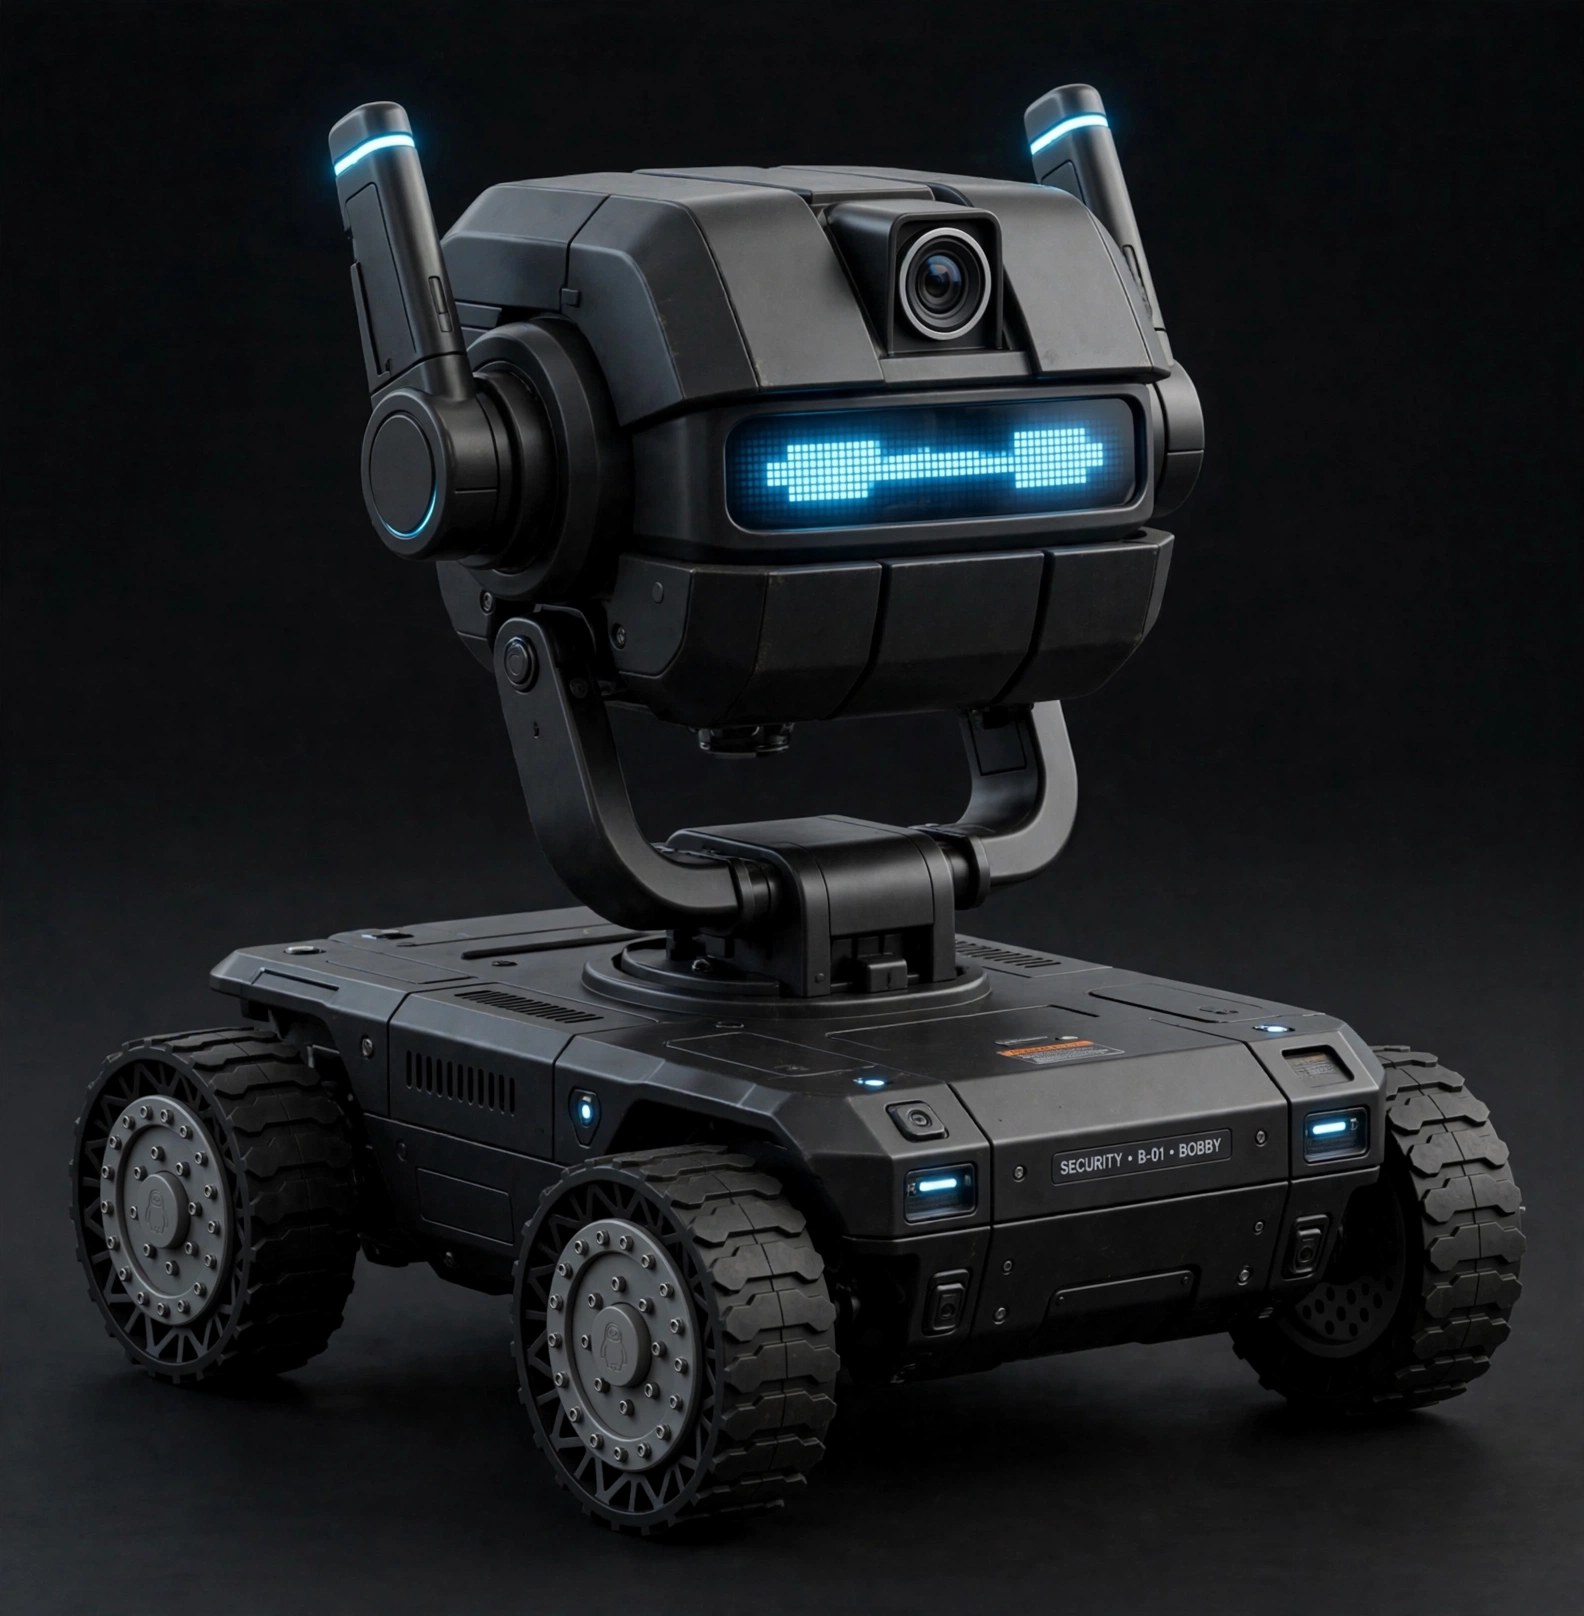
Architecture, parts, CAD. Every subsystem decided on paper before plastic melts.
Test wheel, bench electronics, prove the spine board and drive.
Full chassis, head, wiring. Bobby rolls under his own power.
Sensor expansion, IR homing dock, polish. Then mischief.
Every past Pi/Arduino project ended in a harness hairball. This time the fix is a custom spine PCB: six tidy runs, everything else plugs in.
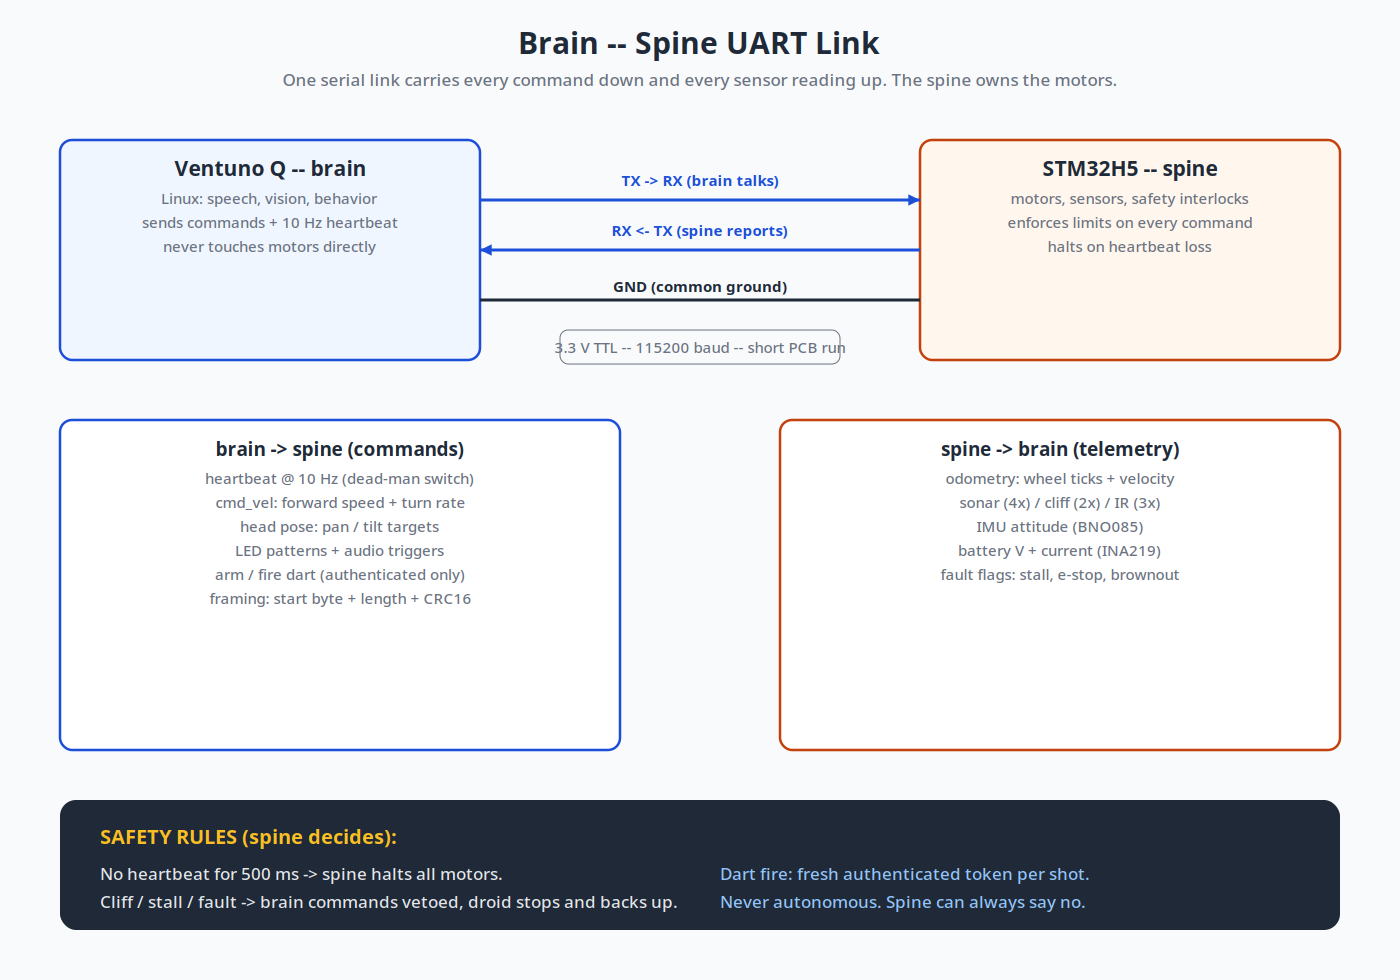
One UART link between the Ventuno Q brain and the STM32H5 safety spine — with a dead-man heartbeat so a crashed brain can't drive the droid into a wall.
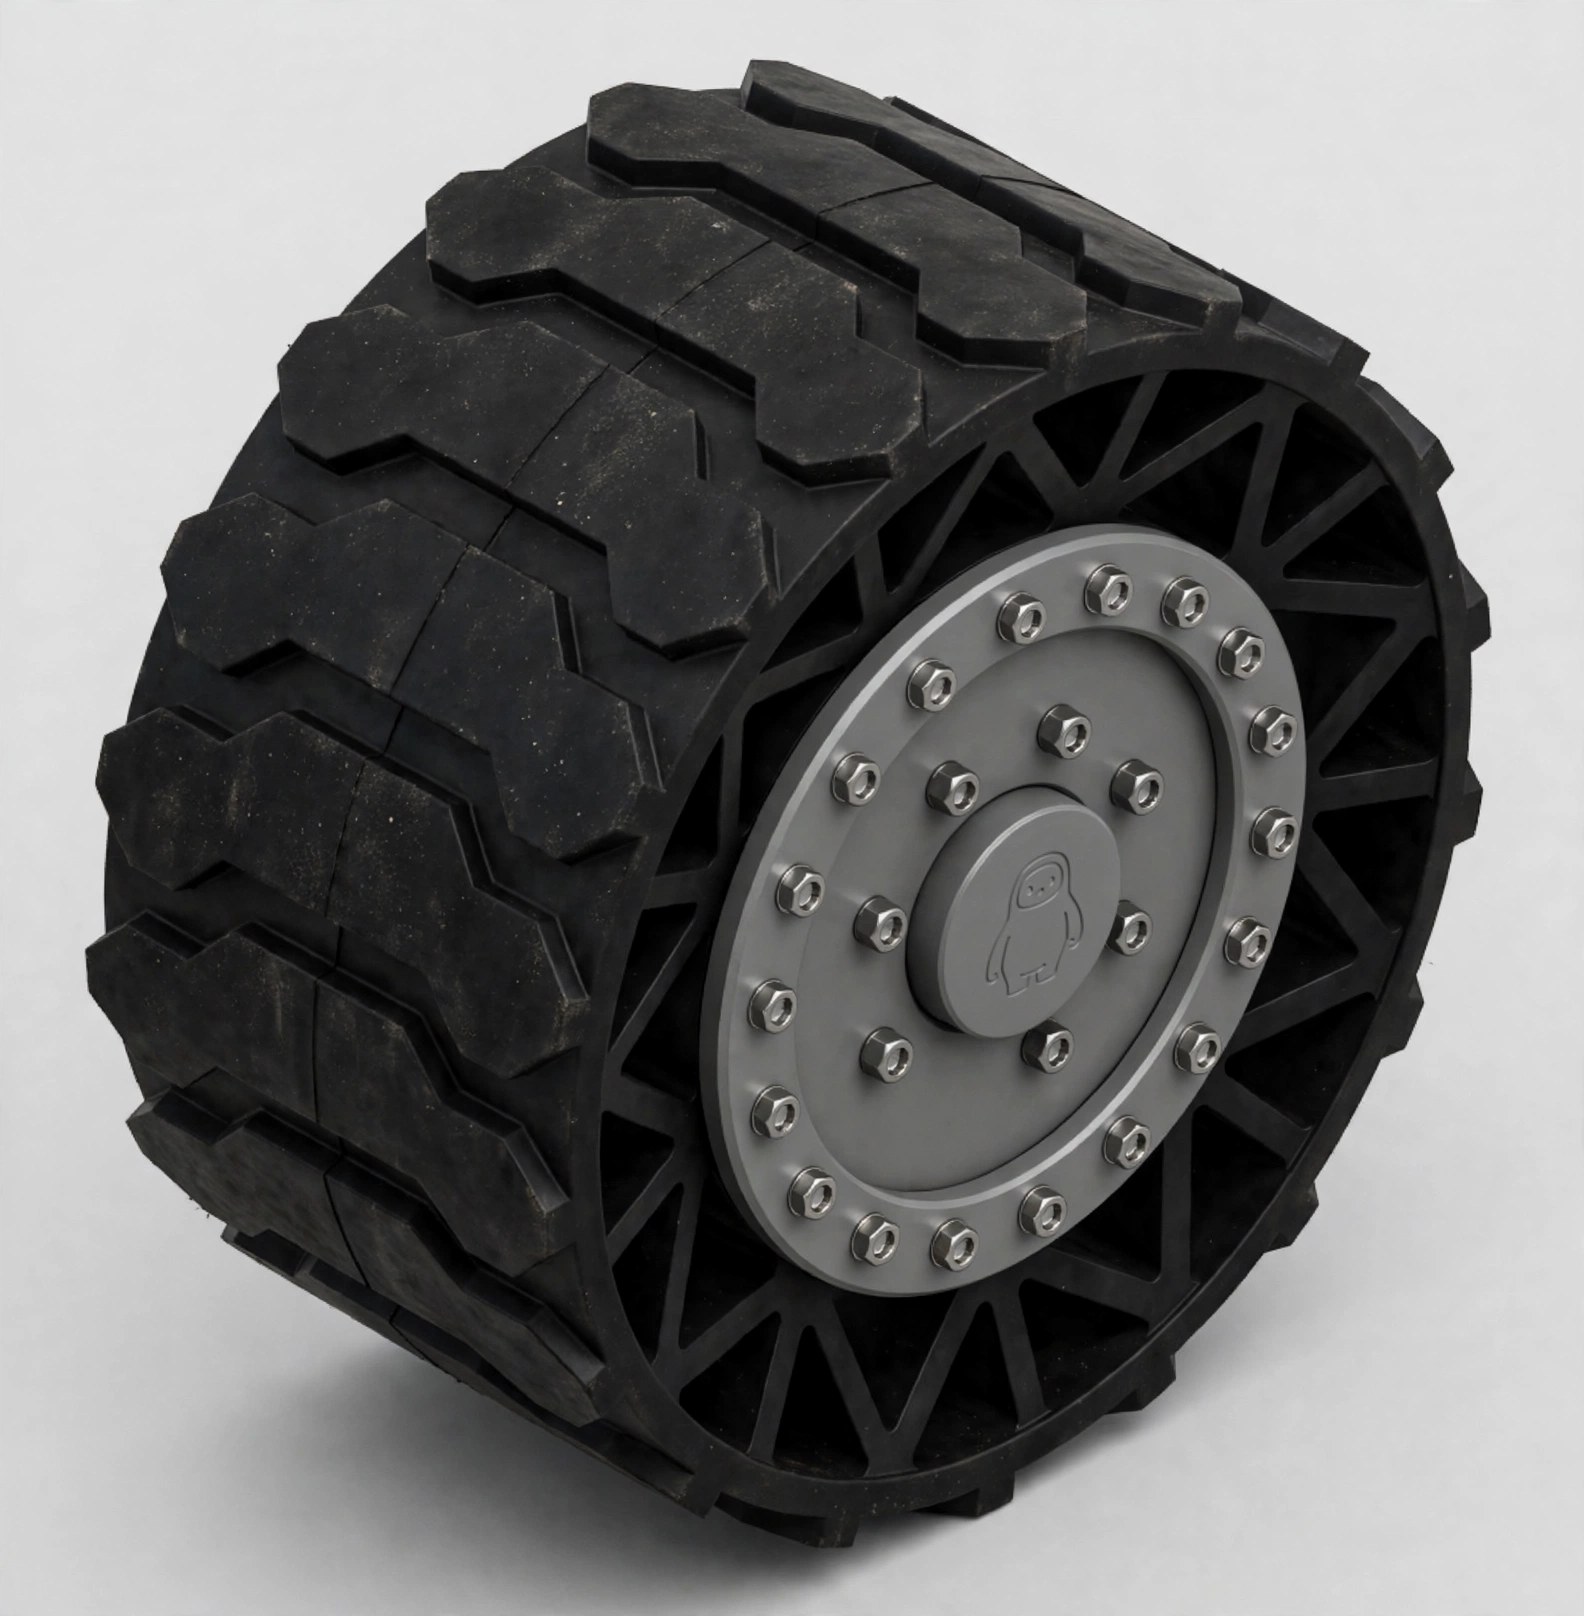
Two-piece beadlock rim, chevron tread that bridges the tire seam, and a Bobby portrait embossed on the cap. One test print before the other three.