Brain suggests, spine decides
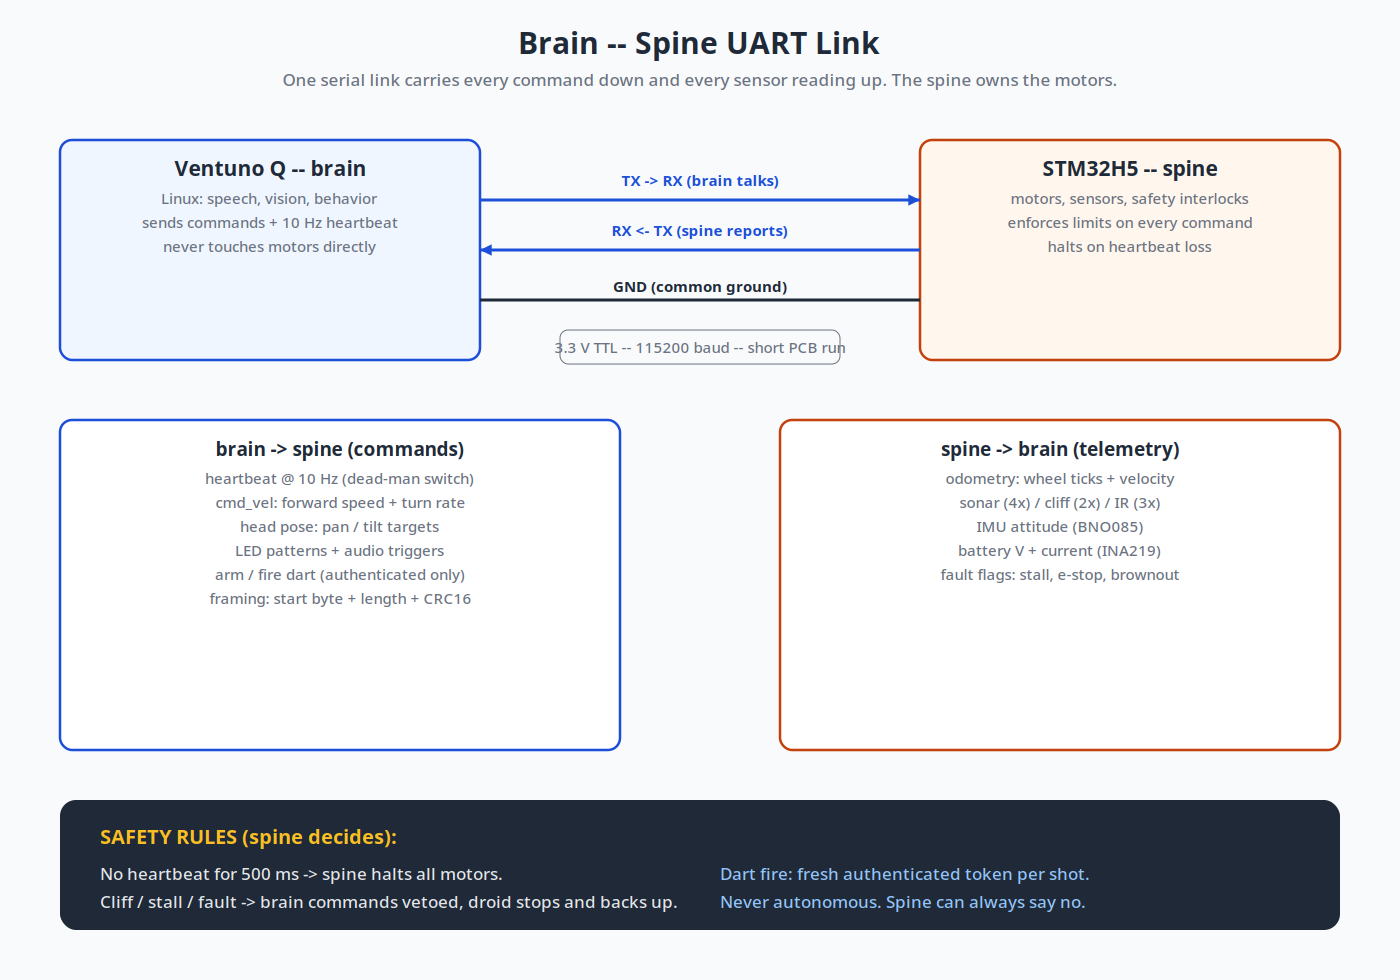
The whole brain/spine relationship rides on one serial link: TX, RX, GND at 3.3 V and 115200 baud, a short run on the spine board. Simple wire, serious protocol.
Packets are framed with a CRC, and the brain sends a heartbeat ten times a second that doubles as a dead-man switch. Miss it for 500 ms and the spine halts the motors by itself — a crashed Linux brain can't drive the droid into a wall.
What flows each way
Down: velocity commands, pan/tilt targets, LED patterns, audio triggers — and dart fire only with a fresh authenticated token per shot, never autonomous. Up: wheel odometry, sonar/cliff/IR readings, IMU attitude, battery voltage and current, fault flags.
The spine enforces the safety rules regardless of what the brain asks. Cliff sensor trips? The brain gets vetoed, the droid stops and backs up. That's not a suggestion. That's the architecture.
← Back to the build log