Hello, Josh: meet Bobby
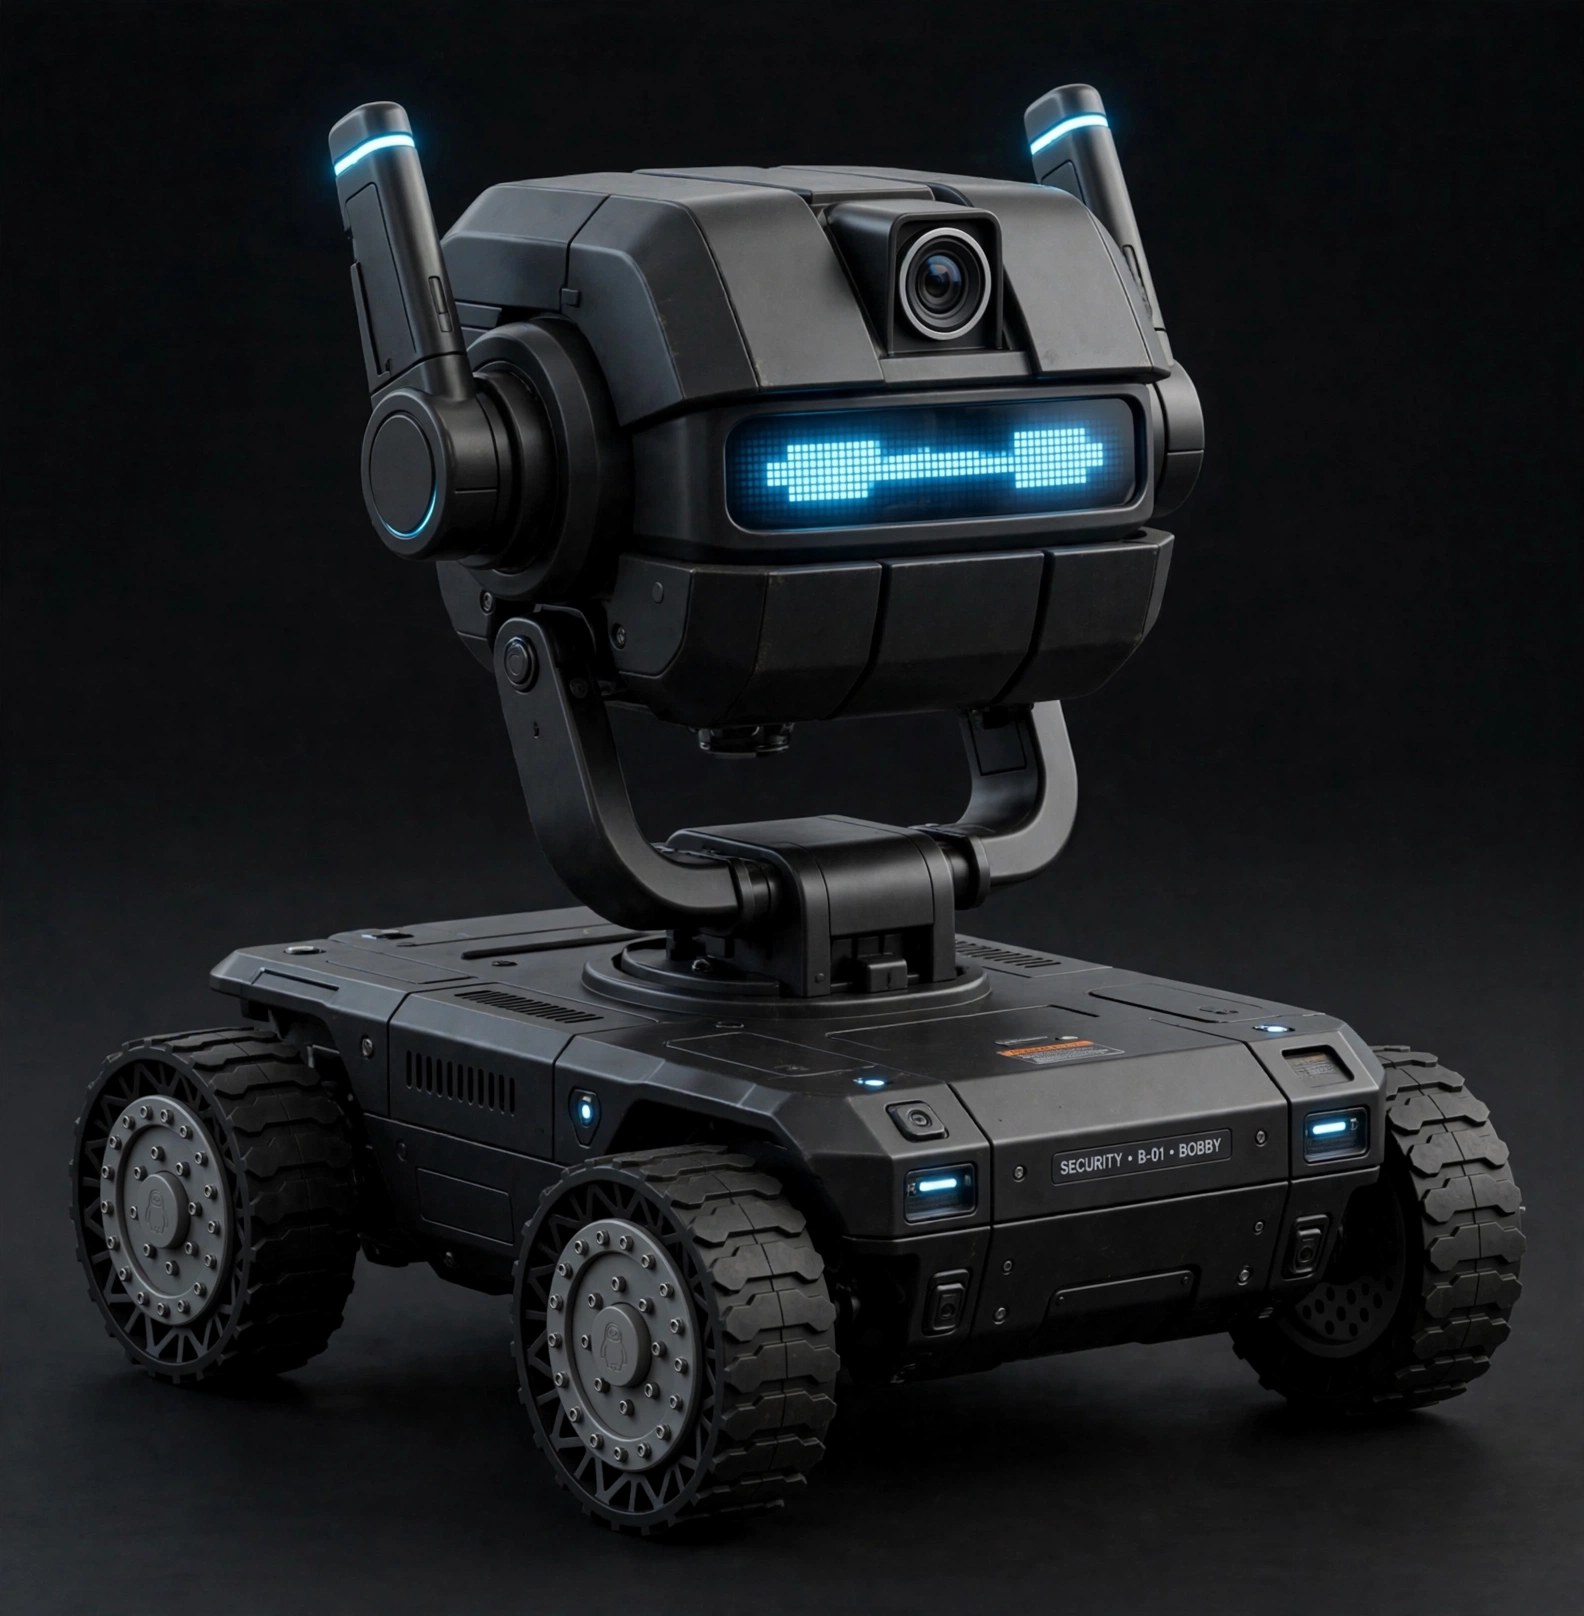
Every good build starts with a sentence. Here's ours: Bobby is a friendly droid — a rolling companion with a pan-tilt head, a camera eye, and just enough personality to feel like a friend instead of an appliance. His first words will be "Hello, Josh."
The architecture is two computers with a clear chain of command. The brain is an Arduino Ventuno Q running Linux — speech, vision, behavior. The spine is an STM32H5 microcontroller — motors, sensors, power, and safety. The rule that governs everything: the brain can suggest; the spine decides. If the brain crashes or commands something unsafe, the spine halts the droid on its own.
PROJECT CONSTRAINTS
| Budget | $1,000 all-in, tracked publicly |
| Drive | 4-wheel skid steer (tank tracks rejected — too WALL-E) |
| Size | ~370 × 295 × 155 mm, ~3.5 kg — backpack-portable |
| Motors | 4× JGB37-520 gearmotors, 12 V |
| Philosophy | Simplify the gribbles. Functional first, pretty later. |
This series follows the build phase by phase: planning, first prints, rev-1 assembly, then rev 2 with a homing dock. Nothing is purchased until the plan earns it.
← Back to the build log